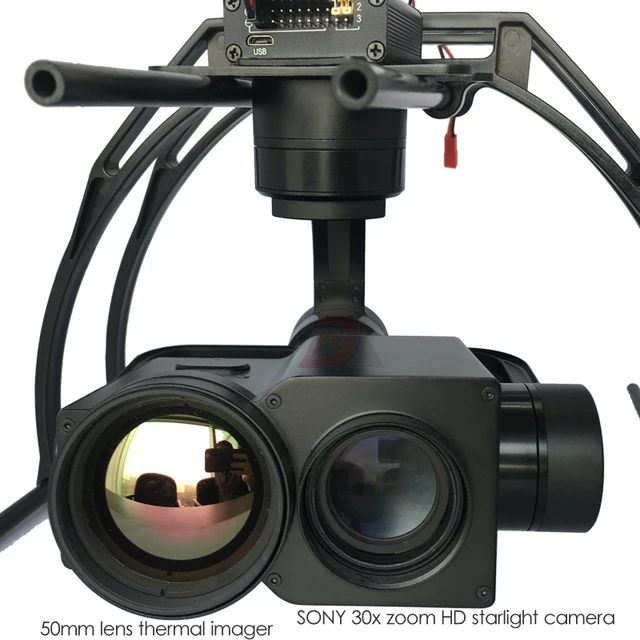
Drone UAV Target Tracking 30x Zoom Visible Optical Camera Infrared Thermal Imaging Camera
| SONY EV7520 30x Starlight Camera |
|
| Imager sensor |
1/2.8-typeExmor R CMOS |
| Lens |
30x zoom 4.3 ~129 mm F1.6 to F4.7 |
| Digital zoom |
12x (360x with optical zoom) |
| Minimum illumination |
Colour: 0.01 lx(F1.6, AGC on,1/30 s) |
| S/N ratio |
More than 50 dB |
| Backlight compensation |
YES |
| High Definition |
1920x1080P(Full-HD) |
| Minimum object distance |
10 mm (wide end) to 1200 mm (tele end)
(Default: 300 mm)
|
| Video Output |
HDMI/SDI/SD Card/RJ45 |
| 640 50mm Thermal Imager |
|
| Detector |
Uncooled long wave (8μm~14μm) thermal imager |
| Detector pixel |
640X480 |
| NETD |
≤50mK (@25℃) |
| MRTD |
≤650mK(@characteristic frequency) |
| Lens |
50mm |
| Color palette |
Black, white, pseudo color |
| Gimbal Description |
|
| Power Consumption |
Quiescent 400mA@12V, Working 500mA@12V |
| Pitch angle range of action |
-90°~+90° |
| Roll angle range of action |
-85°~+85° |
| Yaw angle range of action |
-170°~+170° |
| Angle jitter |
pitch and roll direction±0.01° ,horizontal direction±0.01° |
| Size |
L162.5mm*W164.2mm*H146.5mm |
| Weight |
1210g |
Object Tracking Function
1. Function description
B u i l d -in normalization, cross-correlation and tracking algorithm,combining with object missing recapture algorithm, achieve stable track of the target. Support custom characters of user OSD, adaptive gate, cross cursor,tracking information display.
2. Tracking Performance
1 ) U pdate rate of deviation pixel 50Hz
2) Output delay of deviation pixel <15ms
3) Minimum object contrast 5%
4) The minimal signal-to-noise ratio (SNR) 4
5) Minimum object size 16*16 pixel
6) Maximum object size 160*160 pixel
7) Tracking speed 32 pixel/frame
8) The mean square root values of pulse noise in the object position<0.5pixel
9) Object memory time 100 frames


 Connection of control box and wiring instructions

Camera control line
Zoom: camera zoom control line,connect PWM receiver on third gear, or rocker.
Focus: camera manual focus control line, connect receiver on third gear, or rocker. If not connect, the camera will focus automatically after zooming.
Pic/Rec: photography/video, mode switching, video and photography control, connect receiver on third gear.
Switch from middle to high: photography/video mode switching
Switch from middle to low: (1)In the video mode:if video record is stop , video record starts ,if video record
is starting , switch from middle to low again, the video record will stop; (2)In the photo mode: take a pictures.
Multi: Multi control channel for other function, such as tracking, laser light. IR cut , etc
AV: analog output signal.
Pod PWM signal instructions:
YAW directional channel: speed mode ,connect rocker channel, (or third gear switch channel, stopping need third to middle position.)
PITCH Pitch channel: speed mode ,connect rocker channel, (or third gear switch channel, stopping need third gear to middle position.)
MODE gimbal one button back and speed adjustment:angle mode, A knob or a thirt gear channel switch.
The speed of focusing
Design for UAV aerial photography , according to aerial
characteristics, using fast focus algorithm, focus time <1s.
More technical support. Please contact us!




Follow us on: